Gujarat Technological UniversitySummer 2026 examination

GTU BE04000041 Control Systems Summer 2026 Question Paper & PDF

B.E. · EC Engineering · Semester 4 · Subject code BE04000041
Download official PDFView PDF here
Share with your class
Total
70 marks
To pass
23 marks (33%)
Duration
2.5 Hours 10:30 AM – 1:00 PM
Questions
5 with internal choice
No solutions on this paper yetNeed them for your exam? Ask once. Papers that students ask for are solved first, and we aim to add them within 24 hours.

Q.1

14 Marks
(a)
3 marks
Draw the block diagram of a closed loop control system and explain its components.
(b)
4 marks

For a unity feedback system with forward path transfer function as given below, obtain the steady state error coefficients for step, ramp and parabolic input.

G(s)=10(s+1)s(s+2)(s+5)G(s) = \dfrac{10(s+1)}{s(s+2)(s+5)}

(c)
7 marks
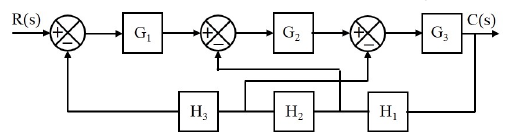
Obtain the transfer function for the block diagram shown in the fugure below
GTU Control Systems (BE04000041) Summer 2026 Question 1(c) Diagram

Q.2

14 Marks
(a)
3 marks
Derive the expression of time response of a first order system to a unit step input.
(b)
4 marks

For the closed loop transfer function given below, obtain the range of K for which the system is stable.

C(s)R(s)=Ks(s+4)(s2+s+1)\dfrac{C(s)}{R(s)} = \dfrac{K}{s(s+4)(s^2+s+1)}

(c)
7 marks
Define (1) time response (2) rise time (3) peak time (4) delay time (5) peak overshoot (6) settling time (7) steady state error
(c)
7 marks

Derive the time response expression of a second order system with closed loop transfer function as given below to a step imput.

C(s)R(s)=ωn2s2+2ζωns+ωn2\dfrac{C(s)}{R(s)} = \dfrac{\omega_n^2}{s^2+2\zeta\omega_n s+\omega_n^2}

Q.3

14 Marks
(a)
3 marks
Comments on the correlation between time and frequency domain.
(b)
4 marks

Determine the stability of a system having characteristics equation as given below using routh's criteria and comment on the location of roots

s5+s4+24s3+48s2−25s−5=0s^5 + s^4 + 24s^3 + 48s^2 - 25s - 5 = 0

(c)
7 marks

Draw the root locus plot for a system having open loop transfer function as following

G(s)H(s)=Ks(s+3)(s2+2s+2)G(s)H(s) = \dfrac{K}{s(s+3)(s^2+2s+2)}

(a)
3 marks
Discuss Nyquist stability criterion in brief.
(b)
4 marks

Comment on the stability of a system having following characteristics equation

s6+3s5+5s4+9s3+8s2+6s+4=0s^6 + 3s^5 + 5s^4 + 9s^3 + 8s^2 + 6s + 4 = 0

(c)
7 marks

Obtain the root locus plot of a system with open loop transfer function as following

G(s)H(s)=Ks(s+1)(s+2)(s+4)G(s)H(s) = \dfrac{K}{s(s+1)(s+2)(s+4)}

Q.4

14 Marks
(a)
3 marks
Can the use of proportional controller result in zero steady state error? Why?
(b)
4 marks
Write down the steps to construct a polar plot.
(c)
7 marks

Obtain gain margin and phase margin for a system with following open loop transfer function. Also comment on the stability.

G(s)=800(s+2)s2(s+10)(s+40)G(s) = \dfrac{800(s+2)}{s^2(s+10)(s+40)}

(a)
3 marks
What is a controller? Why there is a need of a controller in a closed loop control system?
(b)
4 marks
Define (1)gain margin (2)phase margin (3)gain crossover frequency (4)phase crossover frequency
(c)
7 marks

A unity gain feedback system has forward path transfer function as following, obtain gain margin, phase margin and comment on the stability.

G(s)=80s(s+2)(s+20)G(s) = \dfrac{80}{s(s+2)(s+20)}

Q.5

14 Marks
(a)
3 marks
Write and prove any three property of state transition matrix.
(b)
4 marks
Write the standard transfer function of a phase lag network and draw it's bode plot.
(c)
7 marks

Obtain the state transition matrix for the system described by following state model

x˙=[01−20]x+[10]u, y=[1−1]x\dot{x} = \begin{bmatrix} 0 & 1 \\ -2 & 0 \end{bmatrix} x + \begin{bmatrix} 1 \\ 0 \end{bmatrix} u,\ y = \begin{bmatrix} 1 & -1 \end{bmatrix} x

(a)
3 marks
Define (1) state variable (2) state vector (3) state space
(b)
4 marks
Classify the compensation techniques and explain any one in brief.
(c)
7 marks

For the given state model obtain the transfer function.

x˙=[−2−342]x+[35]u, y=[11]x\dot{x} = \begin{bmatrix} -2 & -3 \\ 4 & 2 \end{bmatrix} x + \begin{bmatrix} 3 \\ 5 \end{bmatrix} u,\ y = \begin{bmatrix} 1 & 1 \end{bmatrix} x

Preparing with friends?

Send this paper to your class group. Every question has its own link.

About this paper

Official Gujarat Technological University (GTU) examination paper for Control Systems (Summer 2026, B.E. · EC Engineering, Sem 4). Features complete 70-mark regular & remedial examination pattern, official marking distribution across all 5 questions, and direct 1-click official PDF download.

Transcribed for student exam preparation from Gujarat Technological University official examination archives. Questions, syllabus guidelines, and curriculum marking schemes remain the intellectual property of Gujarat Technological University.

ViewDownload PDF